Embedded systems / RoboticsCompleted
4am — Autonomous Sumo Robot.
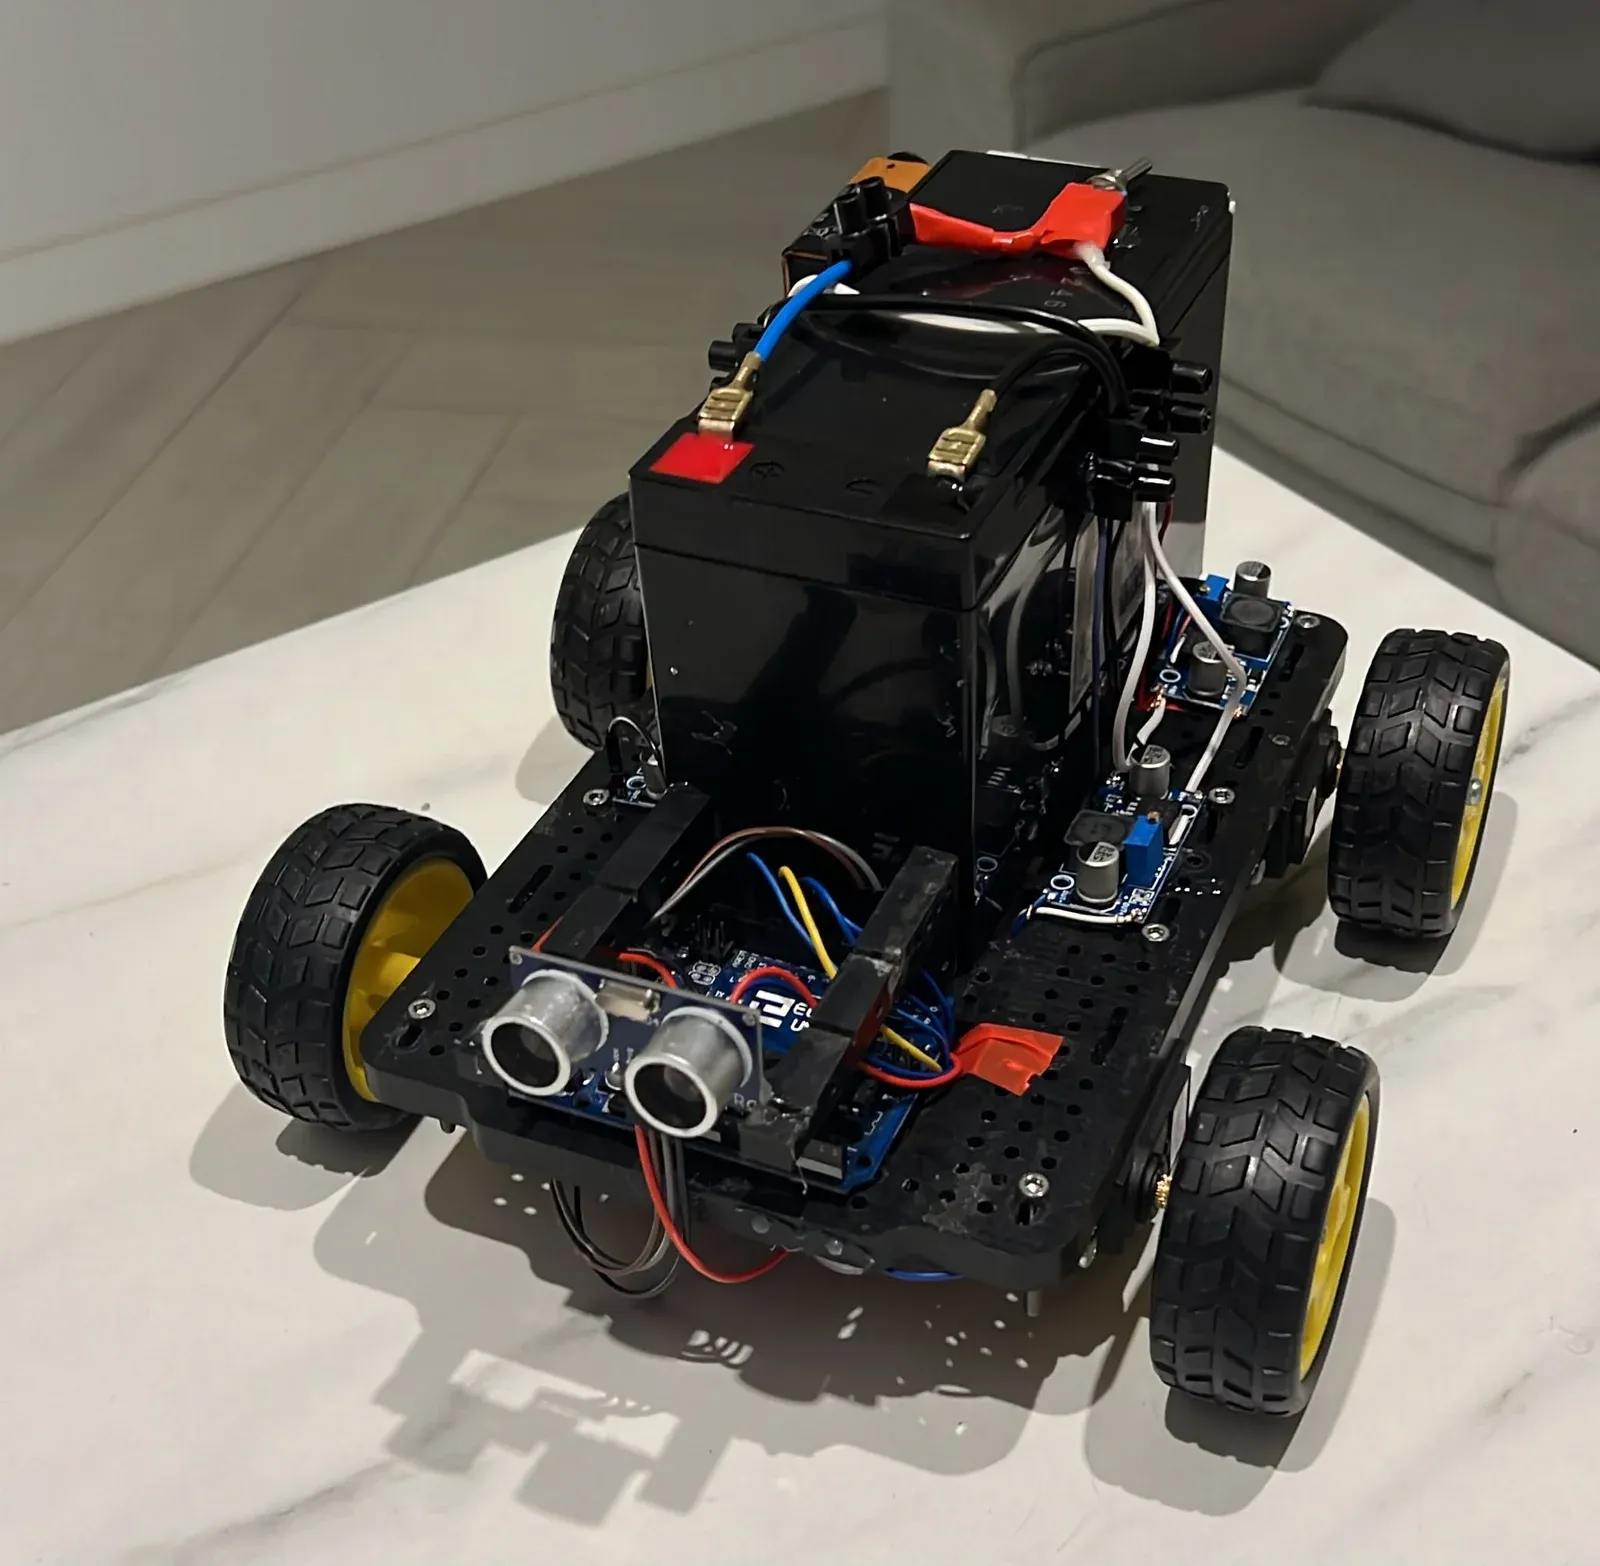
An AVR-based robot that detects opponents, moves to attack, and avoids the arena’s black boundary line. Built as a university course team project.
Functionality
Built by a two-person team, the robot uses ultrasonic and infrared sensors to detect an opponent and avoid the black boundary line around the competition area. Its embedded logic controls movement and attack behaviour.
My contributions
- Hardware selection, 3D printing, and physical assembly.
- Wiring, cable organisation, soldering, and electrical and power integration.
- Embedded control logic and C programming for AVR.
The main integration challenges were thermal management, heat dissipation around the motors, and fitting the wiring and hardware into the chassis.
Results
Our robot finished the end-of-course competition undefeated. I also received an Honors Distinction in the course. These results relate to the university course project.
See the robot in the course competition video.
Gallery